The Determ RViz2 Viewer is a ROS 2 package that provides visualization and management capabilities for Determ 3D Scene Capture devices. This document explains how to set up, configure, and use the package.
Prerequisites
ROS 2: Humble
Ubuntu 22.04
Determ 3D Scene Capture device(s)
Determ Flowbit library 1.3x /1.4x installed (If not installed, download the built library as described in the instructions below).
Installation
1 . Install ROS 2 Humble
The official ROS 2 Humble installation guideline is here
Download the zip file and unzip the file in some folder.
Edit the CMakeLists.txt file to point to your FlowBit SDK installation directory:
Update the path to your FlowBit SDK library as shown below:
set(CMAKE_INSTALL_RPATH "${CMAKE_INSTALL_PREFIX}/lib:$ENV{HOME}/Determ/Library/determ_flowbit_server/lib/release")
# For example, if you download and unzip the folder in ~/Determ/Library, it would be # set(CMAKE_INSTALL_RPATH"${CMAKE_INSTALL_PREFIX}/lib:$ENV{HOME}/Determ/# Library/determ_flowbit_server/lib/release")
6. Build the Package
source /opt/ros/humble/setup.bash # Source the Humble setup file in the correct path# Note: Replace .bash with your shell if you’re not using bash.#Possible values are: setup.bash, setup.sh, setup.zsh.cd ~/ros2_ws
colcon build --packages-select determ_rviz_viewer --cmake-args-Dflowbit-server_DIR=/path/to/your/flowbit-server_DIR
# It is the directory where the unzip fold is.# For example, if the fold download zip is unziped in /home/determ/Determ/Library, then # colcon build --packages-select determ_rviz_viewer --cmake-args -Dflowbit-server_DIR=/home/determ/Determ/Library/determ_flowbit_server/cmake
Usage
1. Launch the Viewer
# Source the workspace
source ~/ros2_ws/install/setup.bash
# Launch with default configuration#The default configuration is in home/determ/ros2_ws/src/determ_rviz_viewer/launch/determ_manager.launch.py. User could modify the setting and rebuild the project with #colcon build --packages-select determ_rviz_viewer --cmake-args -Dflowbit-server_DIR=/path/to/your/flowbit-server_DIR
ros2 launch determ_rviz_viewer determ_manager.launch.py
# Or specify a custom config path
2. Working with Determ Devices
Open another terminal and run the commands as follows:
# Source the Humble setup filesource /opt/ros/humble/setup.bash
# Source the workspacesource ~/ros2_ws/install/setup.bash
# List Available Clients.
ros2 service call /determ/list_clients std_srvs/srv/Trigger # The servive call will list all the clients in the ternimal lauching RViz window.# Set the client ID parameter with the client you want to connect
ros2 param set /determ_manager selected_client_id "SZINDS-000000-XXXXXX-192168-150102"# Connect to the client
ros2 service call /determ/connect_client std_srvs/srv/Trigger
# Start the capture
ros2 service call /determ/connect_capture_client std_srvs/srv/Trigger
# Stop the capture
ros2 service call /determ/disconnect_capture_client std_srvs/srv/Trigger
#disconnect to the client
ros2 service call /determ/disconnect_client std_srvs/srv/Trigger
############################################################################# Work on all clients# Connect all clients available
ros2 service call /determ/connect_all_clients std_srvs/srv/Trigger
# Capture all clients connected
ros2 service call /determ/connect_all_capture_clients std_srvs/srv/Trigger
# Disconnect all clients
ros2 service call /determ/disconnect_all_clients std_srvs/srv/Trigger
# Check the topics list
ros2 topic list | grep
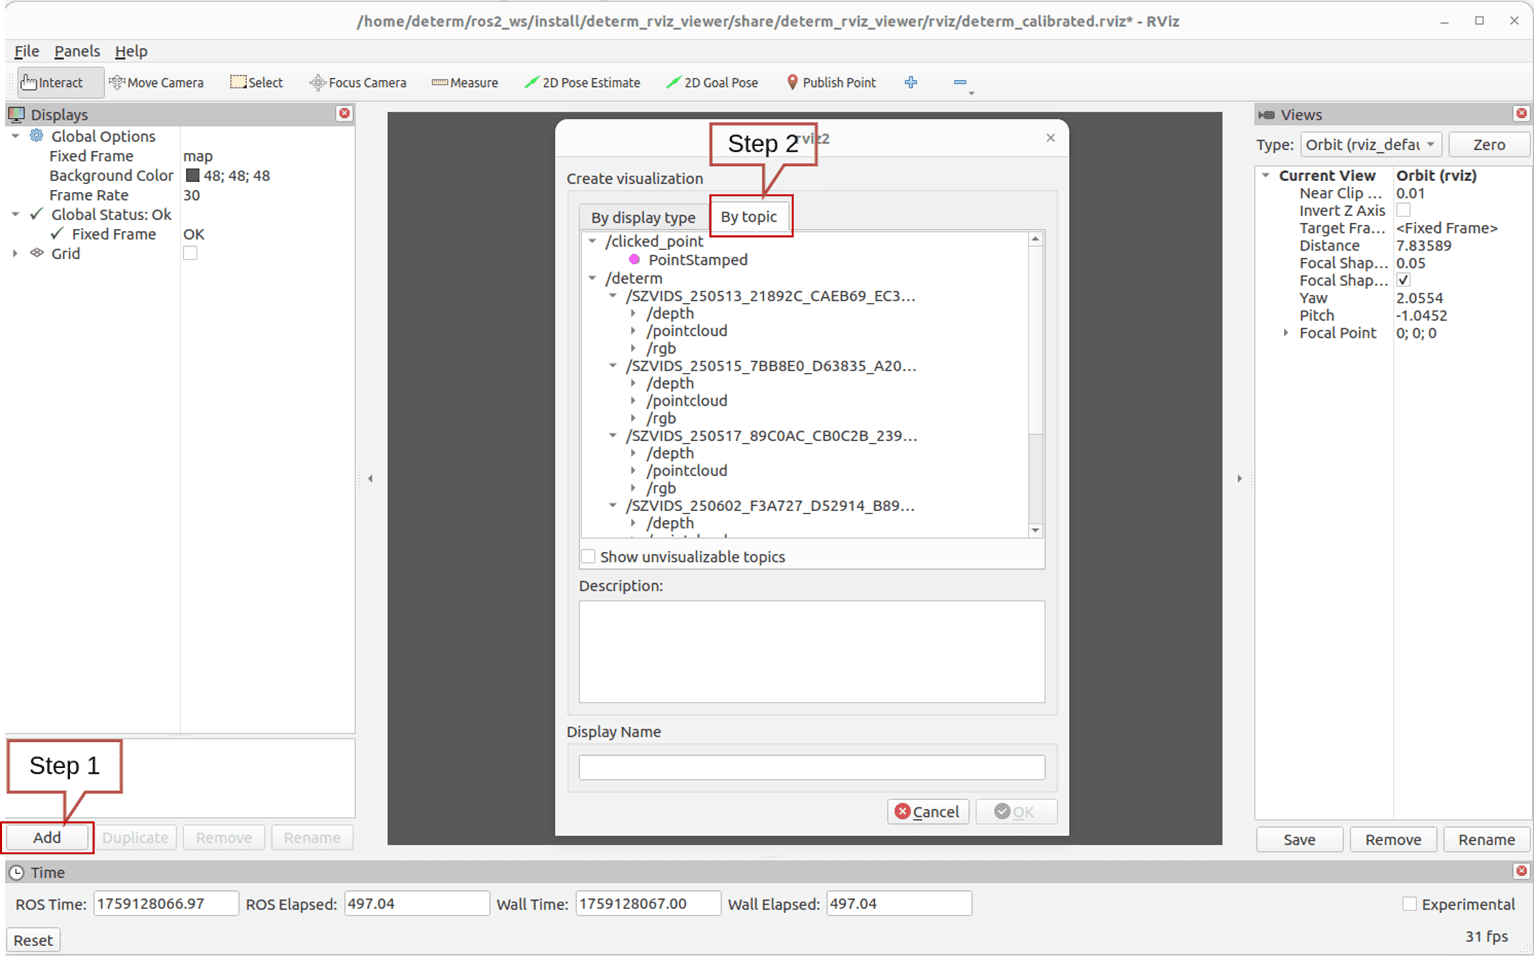
After connecting and capturing clients, you can manually add point cloud, color, and depth images in RViz 2, as shown in the screenshot below.
A Python script is provided to automatically load all connected and available clients:
cd ~/ros2_ws/src/determ_rviz_viewerpython3 generate_rviz_config.py
cd ~/ros2_ws/src/determ_rviz_viewerpython3 generate_rviz_config.py
cd ~/ros2_ws/src/determ_rviz_viewerpython3 generate_rviz_config.py
This will:
Call /determ/list_clients service
Parse all available client IDs
Generate RViz config with displays for ALL of them
Save to ~/.rviz2/determ_auto_generated.rviz
rviz2 -d ~/.rviz2/determ_auto_generated.rviz
rviz2 -d ~/.rviz2/determ_auto_generated.rviz
rviz2 -d ~/.rviz2/determ_auto_generated.rviz
All client point clouds will be visualized in RViz.
If your clients are calibrated, place the calibration JSON file in ~/ros2_ws/src/determ_rviz_viewer/config as calibration.json. An example calibration file is included in the folder. All extrinsic matrix parameters will be loaded for all clients.
When running the commands above, please review the outputs in both terminals to check the status and any errors. Security is built into every layer.
The Package
1. ROS 2 Topics
The package publishes the following topics:
Topic
Type
Description
/determ/status
std_msgs/msg/String
Status messages from the system
/determ/<client_id>/pointcloud
sensor_msgs/msg/PointCloud2
Point cloud data from a specific client
/determ/<client_id>/rgb
sensor_msgs/msg/Image
RGB image from a specific client
/determ/<client_id>/depth
sensor_msgs/msg/Image
Depth image from a specific client
/determ/markers
visualization_msgs/msg/MarkerArray
Markers for client visualization
/determ/transforms
geometry_msgs/msg/TransformStamped
Transform data for the frame hierarchy
2. ROS 2 Services
The package provides the following services:
Service
Type
Description
/determ/list_clients
std_srvs/srv/Trigger
List all available clients
/determ/connect_client
std_srvs/srv/Trigger
Connect to the selected client
/determ/disconnect_client
std_srvs/srv/Trigger
Disconnect the selected client
/determ/connect_capture_client
std_srvs/srv/Trigger
Start capture for the selected client
/determ/disconnect_capture_client
std_srvs/srv/Trigger
Stop capture for the selected client
/determ/shutdown
std_srvs/srv/Trigger
Shutdown the application
/determ/connect_all_clients
std_srvs/srv/Trigger
Connect all the client available
/determ/connect_all_capture_clients
std_srvs/srv/Trigger
Capture all the clients connected
/determ/disconnect_all_clients
std_srvs/srv/Trigger
Disconnect all the clients
3. Parameters
The package uses the following parameters:
Parameter
Type
Description
config_path
string
Path to the Determ configuration directory
publish_pointclouds
bool
Whether to publish point clouds as ROS messages
publish_images
bool
Whether to publish RGB and depth images as ROS messages
update_rate
double
Update rate in Hz for the main processing loop
world_frame_id
string
Frame ID for the world frame
selected_client_id
string
Client ID for client-specific operations
Support
For further assistance, please contact the Determ support team.