Coordinate Systems
This article describes where calibration puts the world origin, which way the axes point, and what changes when you import the result into a Y-up tool.
Calibration measures everything against one anchor. You choose it on card A: either a printed ChArUco board laid on the floor, or one of the cameras. See Capture the Space - Choose a world origin.
The board frame
With the board as the reference, the world frame is:
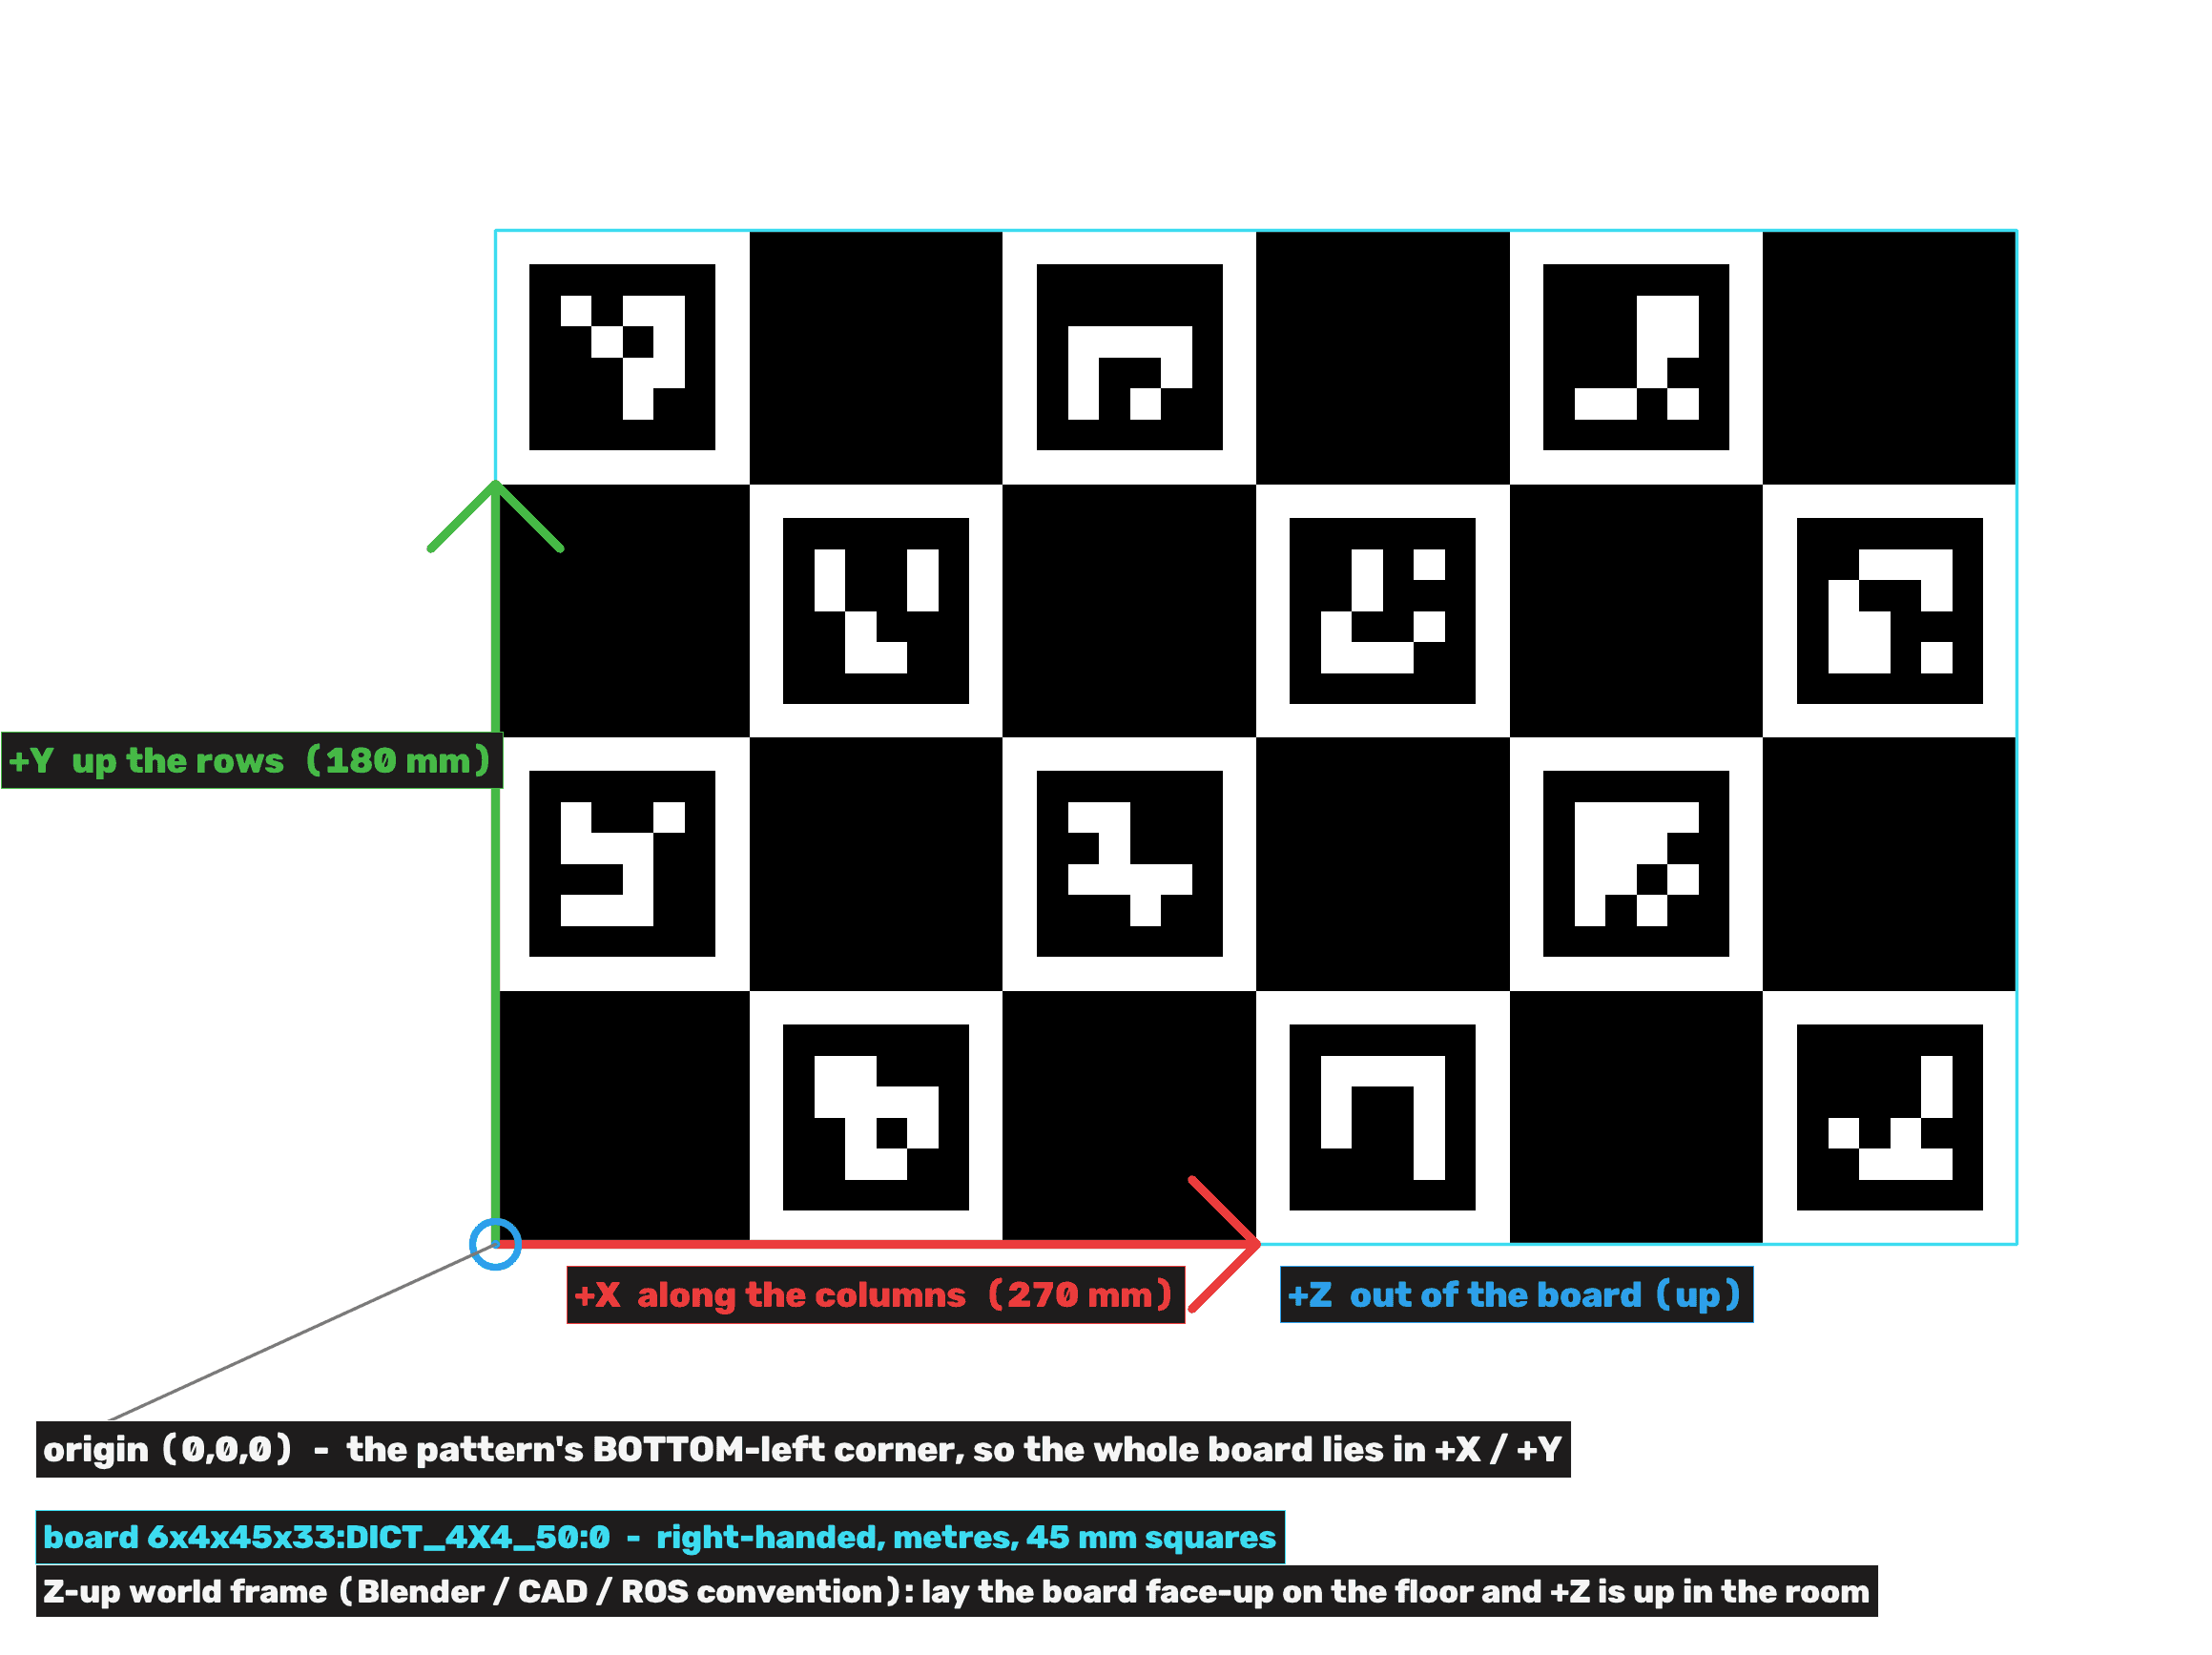
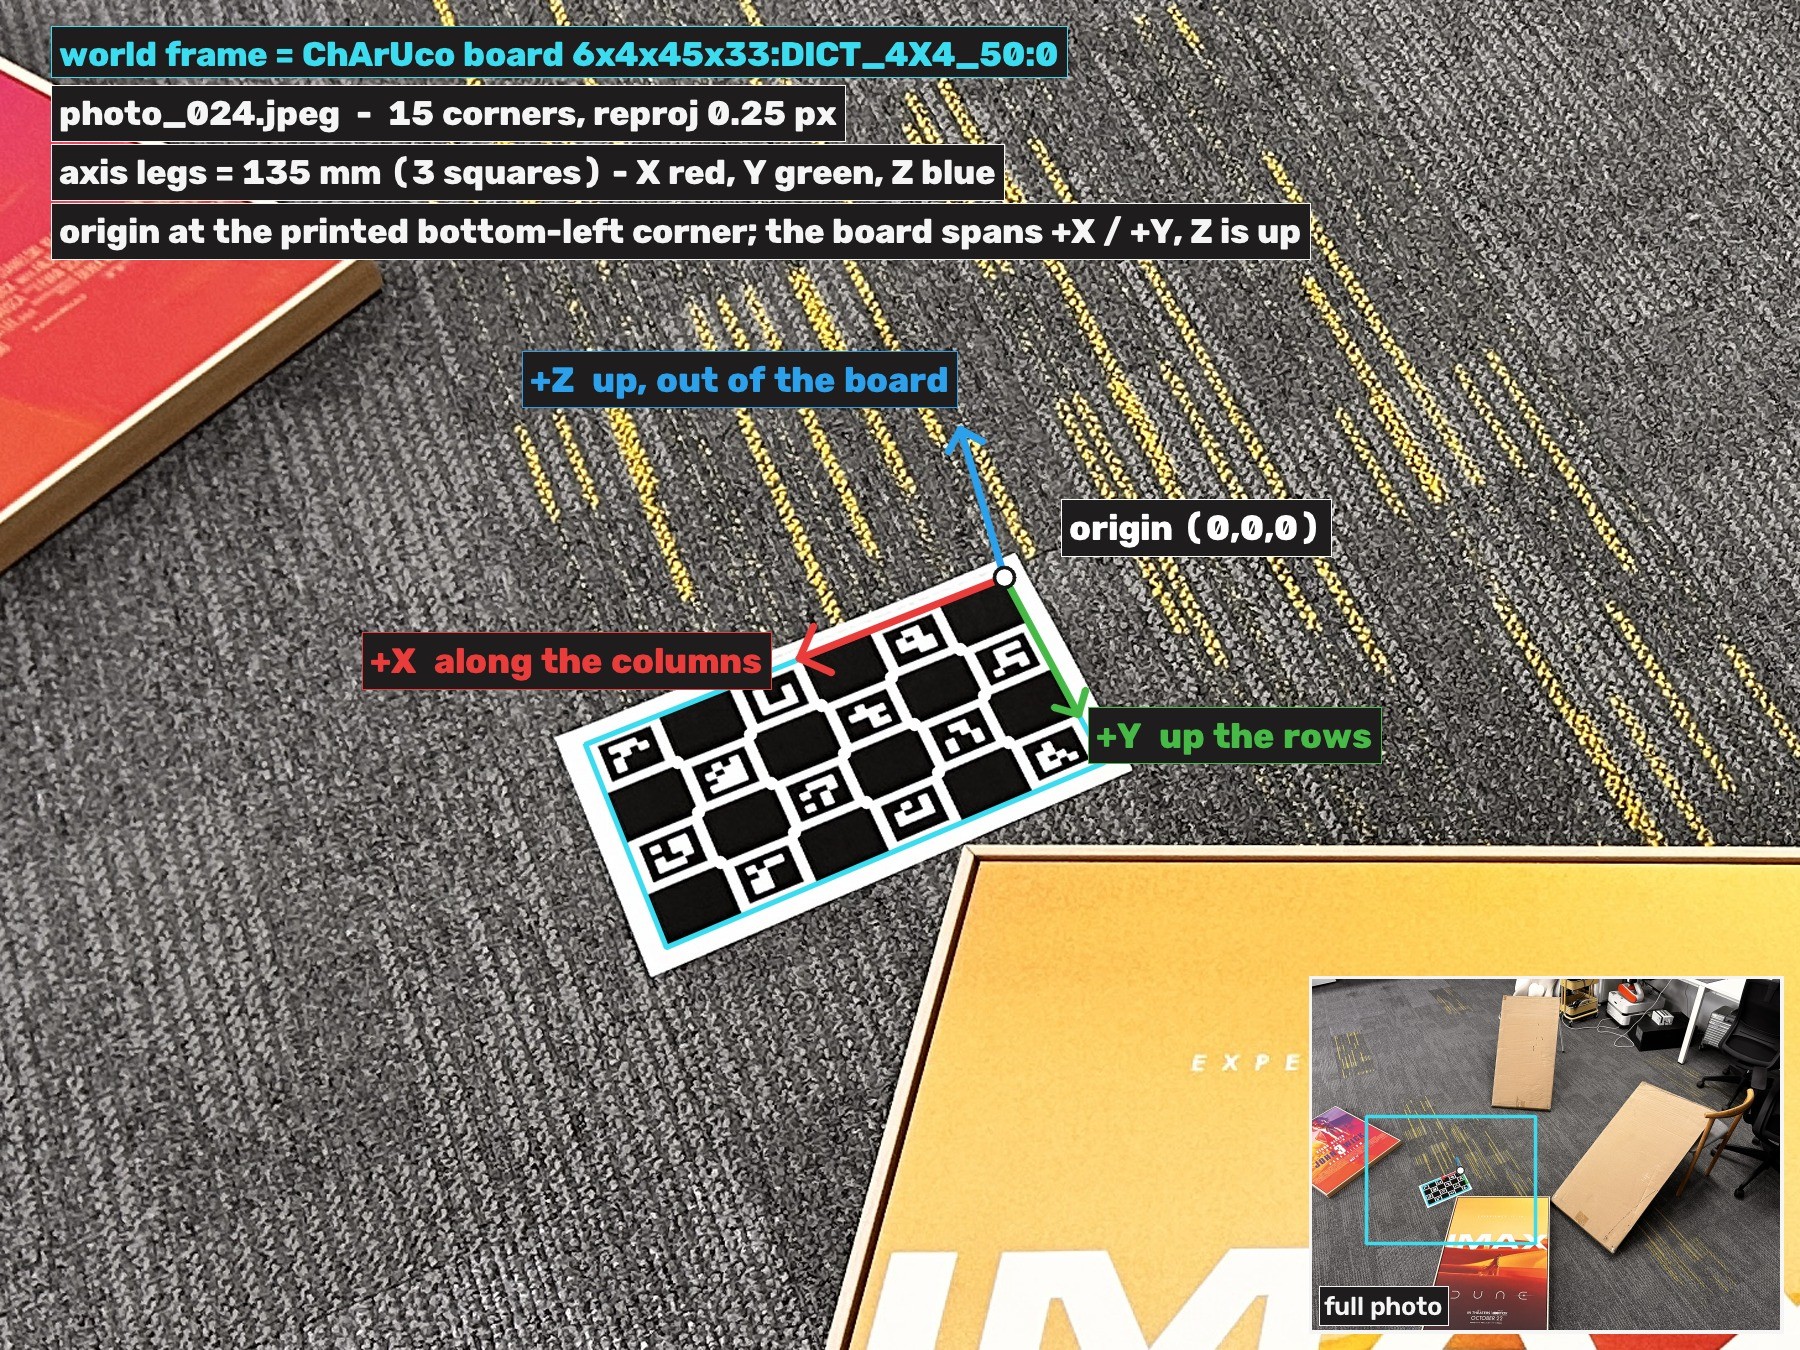
The origin sits at the bottom-left corner of the printed pattern. The whole board lies in +X and +Y.
+X runs along the columns, 270 mm on the shipped board. +Y runs up the rows, 180 mm. +Z comes out of the printed face.
Units are metres, right-handed.
Lay the board face-up and +Z points up in the space. This is the Z-up convention that Blender, CAD and ROS use.
The camera frame
If you use a camera as the reference instead of the board, the world frame is that camera's sensor frame. Pick which camera in Calibrate's Reference option, or leave it on auto.
Z-up and Y-up
Unity, Godot and glTF viewers are all Y-up, so importing this world frame into one of those needs the usual Z-up to Y-up swap.
TODO(software):
Give the exact conversion, and state whether the Unity Plugin applies it for you. See Flowbit Unity Plugin.
Related
Capture the Space - Choose a world origin, for deciding between the board and a camera.
Calibration Settings - Metric scale from, for how the anchor you choose affects the size of the result.