Install Your Devices: Step by Step
Overview
Step | Objective | Completion Criteria |
|---|---|---|
Camera Power-On Test | Cameras are powered on, connected to the network, producing images, and synchronized | All devices are listed in Flowbit Capture and can be previewed simultaneously; sync frame rate is close to 30 Hz |
Camera Installation and Calibration | Fix mounting positions and establish a unified world coordinate system | Cameras share overlapping fields of view; extrinsics are written back to cameras; multi-camera point clouds are aligned |
End-to-End Verification | Capture, rendering, and recognition/segmentation pipeline runs successfully | Viewer displays a fused point cloud with correctly overlaid masks |
Camera Power-On Test
Before mounting the cameras, perform a power-on and connectivity check.
Wiring: Two Power Supply Options
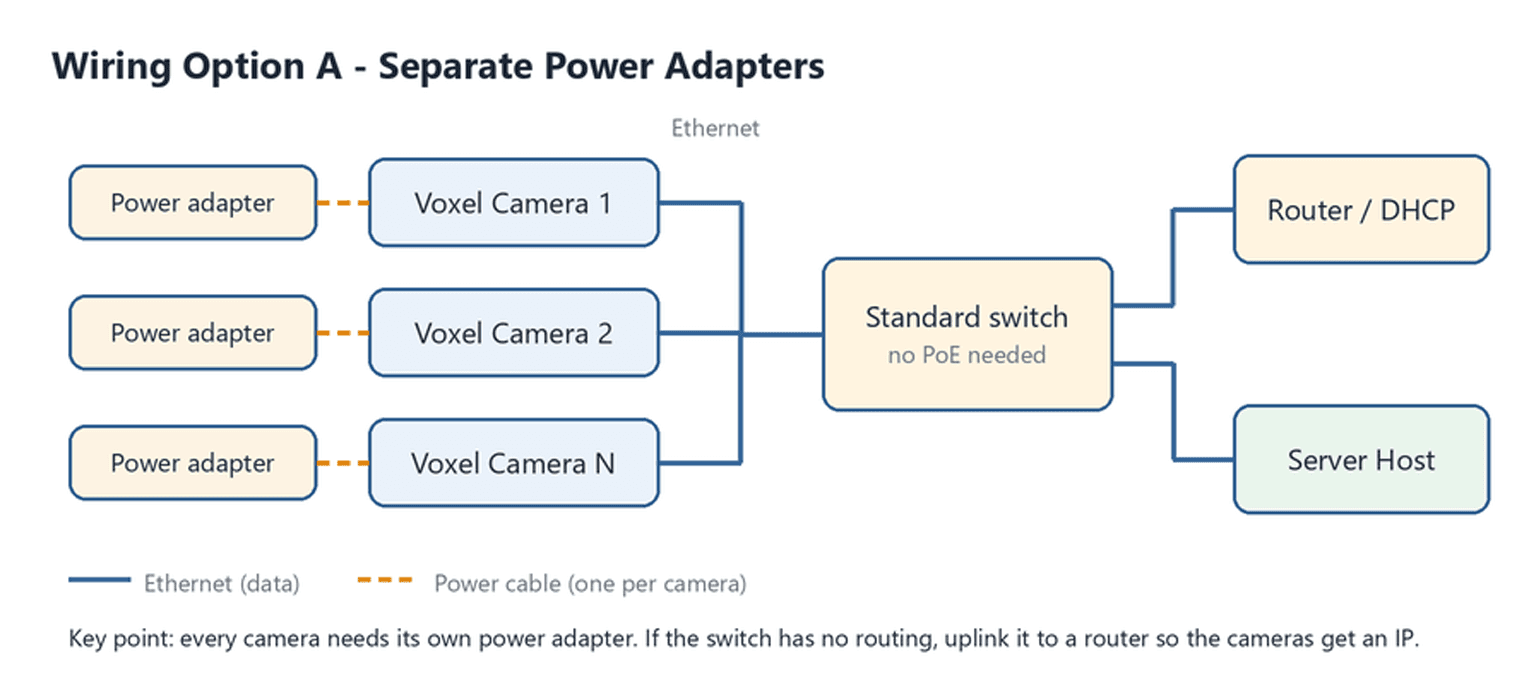
Option A: Dedicated Power Supply
Connect each camera to its power adapter and power it on.
Connect each camera to the switch with an Ethernet cable.
If the switch does not have routing capabilities, connect it to a router so the router can assign IP addresses to the cameras via DHCP.
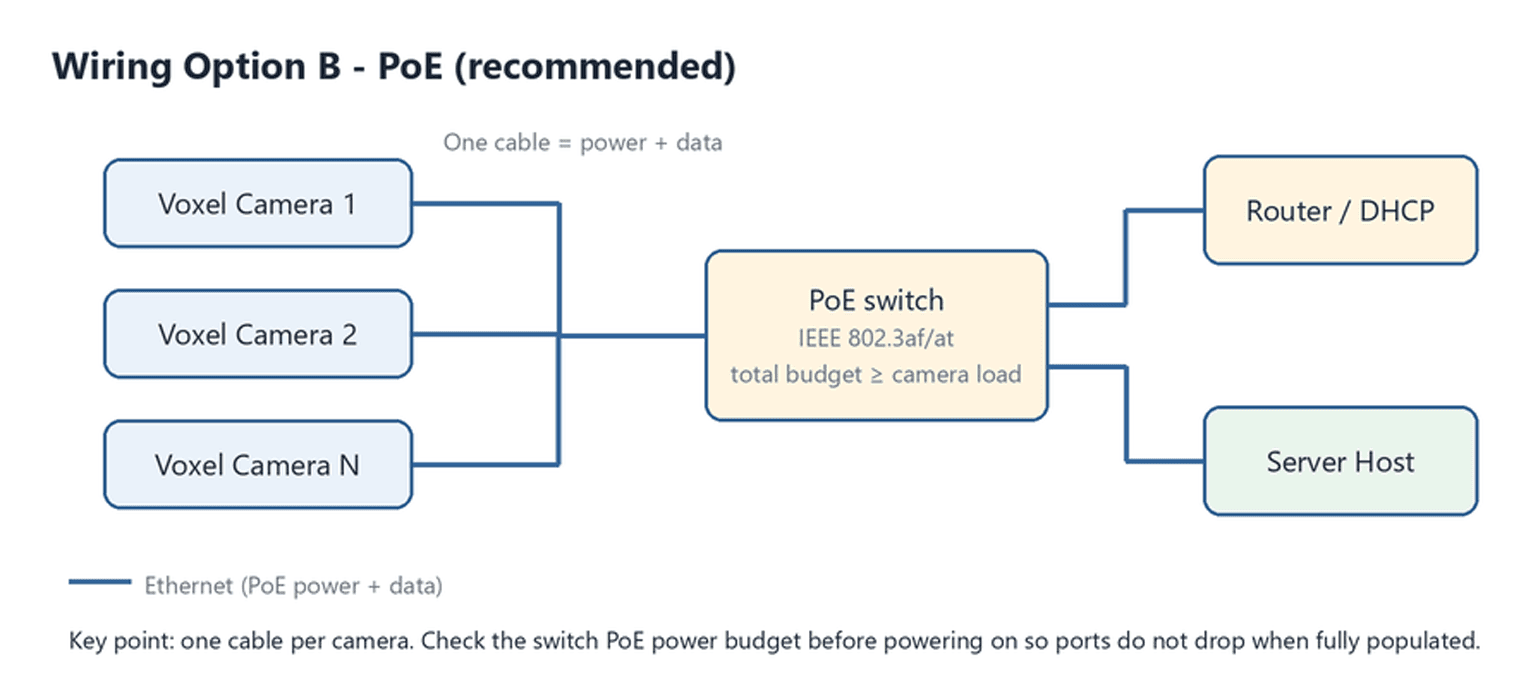
Option B: PoE (Recommended)
Connect each camera to a PoE switch with a single Ethernet cable, which carries both power and data.
If the PoE switch does not have routing capabilities, connect it to a router for IP assignment via DHCP.
Before powering on, verify the switch's total PoE power budget to avoid power drops when all ports are populated.
Status Check: Ethernet Port Indicator LEDs
After powering on and connecting to the network, check the Ethernet port indicator LEDs on each camera:
LED Status | Meaning |
|---|---|
Yellow LED blinking + Green LED solid | Normal: link is established and data is being transmitted/received |
All LEDs off | No power, or Ethernet cable/port fault; for PoE setups, check whether the switch port is supplying power |
Green LED on only, yellow LED not blinking | Physical link is up but no data flow; check whether DHCP has assigned an IP address |
Verify Image Output with Flowbit Capture
Connect the computer to the same network (subnet) as the cameras.
Download and install Flowbit Capture, see Flowbit Capture and Install and Run Flowbit Capture.
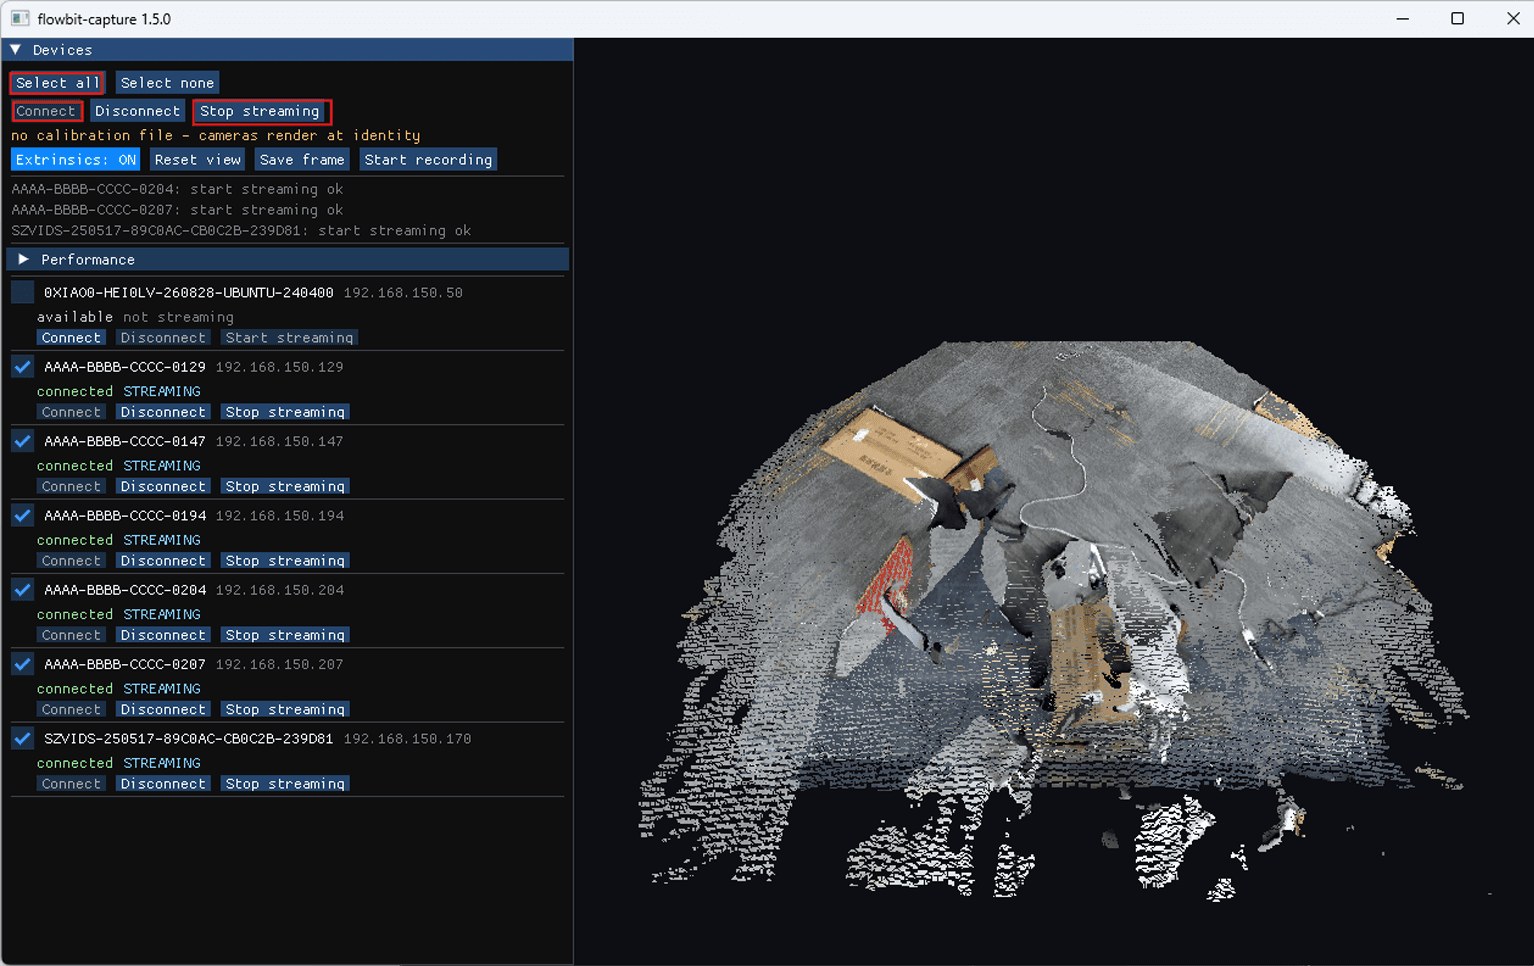
Complete the initial configuration as prompted and launch the application. The Devices panel will list all discovered devices.
Click Select all → Connect → Start streaming.
Expected result: All devices show the status
connected STREAMING, and all camera feeds are displayed correctly.
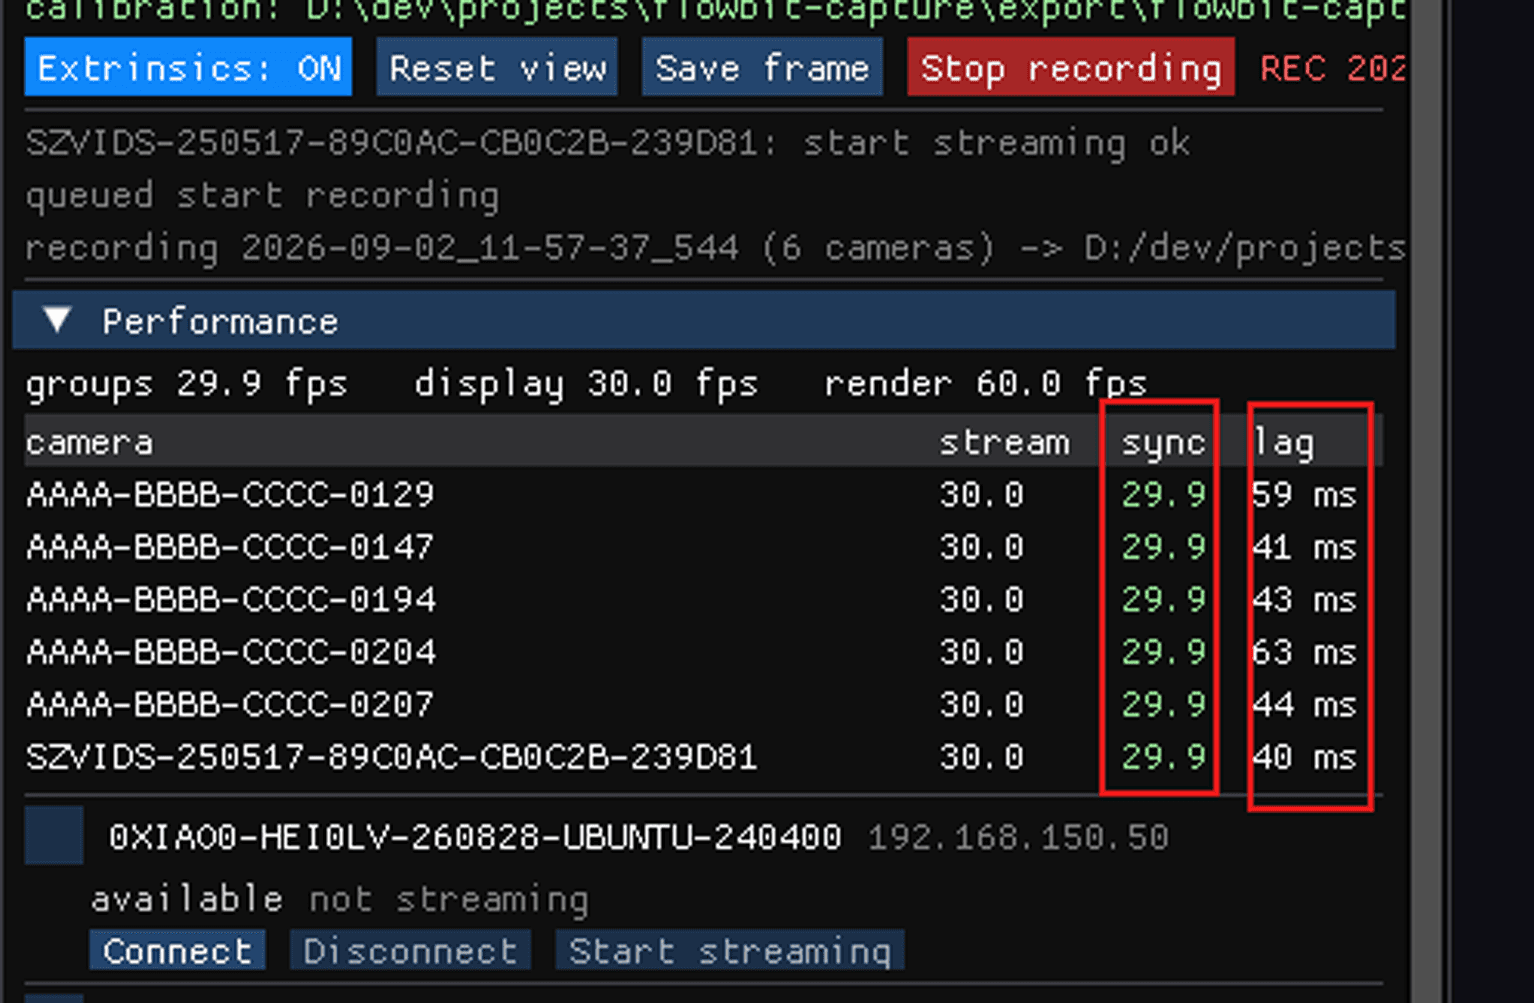
Sync Status Check: Expand the Performance panel and verify the following metrics:
Metric | Description | Acceptance Criteria |
|---|---|---|
Per-camera | Frame rate at which the application receives raw data from the camera | Close to 30 fps |
Per-camera | Per-camera data refresh rate after synchronization | Close to 30 Hz (the smaller the gap with stream, the better) |
Per-camera | Latency between data capture time and sync completion on the application side | Under 1000 ms (typical on-site measurements: 40–60 ms) |
groups | Average frame rate after multi-camera synchronization processing | Close to 30 fps |
display fps | Display refresh rate | Close to 30 fps; may decrease if GPU performance is insufficient |
If the device list is empty or devices are missing:
Symptom | Troubleshooting |
|---|---|
No devices found | The computer and cameras are on different subnets; the mDNS service (Bonjour/avahi) is not running on the host; the firewall is blocking UDP port 5353 |
Some devices missing | Missing devices have not obtained an IP address (check the router's DHCP client list); Ethernet cable/port fault; insufficient PoE power causing some devices to lose power |
Listed but cannot connect | The switch has port isolation enabled; the camera-side application is not running (contact engineering to verify device status) |
Camera Installation and Calibration
Mounting Position Planning
Requirement | Details |
|---|---|
Detection range ≤ 5 m | The distance from the camera to the target area must not exceed 5 m; depth quality degrades significantly beyond this range |
Overlapping field of view | Multiple cameras must cover the same target area with sufficient overlap. This is a prerequisite for multi-view point cloud fusion and ensuring that 3D segmentation does not produce duplicate objects |
Field of view | Single-camera depth FoV: H 75° / V 65°. Use this to estimate coverage per camera, then determine the number of cameras and their spacing |
Mounting height and tilt angle | Mount cameras at a 30–45° downward angle toward the target area; avoid having cameras appear in each other's field of view |
Conditions to avoid | Strong backlighting, direct exposure to windows or highly reflective floors, glass and mirror surfaces, mounting positions where the target is occluded |
Cable routing | Ethernet cables must run uninterrupted from the camera mounting position to the switch, with a maximum single-run length of 100 m; leave slack for subsequent angle adjustments |
Mounting and Angle Adjustment
Secure each camera to the planned position using a 1/4-inch screw mount bracket. Do not fully tighten the bracket yet.
Open Flowbit Capture and start streaming from all cameras simultaneously. Adjust the angle while monitoring the live feed.
Verify each camera individually: the target area falls entirely within the frame, and adjacent cameras have clearly overlapping coverage.
Once the angle is finalized, tighten all bracket joints to prevent displacement from accidental contact or vibration.
Perform calibration only after tightening. The extrinsic parameters are tied to the current physical orientation. If a camera is moved afterward, recalibration is required.
Camera Calibration
The purpose of calibration is to determine the Sensor-to-World extrinsic parameters (4×4 row-major matrix) for each camera, placing all camera point clouds into a unified world coordinate system so that multi-camera point clouds are aligned rather than drifting apart. 3D segmentation and fusion also operate in this unified coordinate system.
Follow the instructions in the Flowbit Calibration software to capture data and calibrate the cameras. The calibration results are written to
calibration_result.json.After calibration is complete, reconnect the devices in Flowbit Capture. The extrinsic matrices will be written to the cameras during reconnection.
After reconnecting, verify that the
"Sensor to World Extrinsic"field in each device'ssensor_config.jsonhas been updated with the latest calibration results.
If Flowbit Capture displays the message
no calibration file — cameras render at identityat the top, the calibration results have not been loaded. All cameras will render using the identity matrix (i.e., all point clouds will be stacked at the world origin).
Calibration result verification:
Observation | Assessment |
|---|---|
Multi-camera point clouds overlap as a single layer in the overlapping region, with the ground plane aligned | Calibration is correct |
Point clouds are layered, misaligned, or show "two ground planes" | Extrinsic parameters are incorrect; recalibrate the affected camera |
Recognition results show duplicates or targets appear at incorrect positions | Extrinsic parameters are incorrect or have not been written back to the camera |
A camera's point cloud appears near the origin | That camera's extrinsic parameters are still the identity matrix, indicating that calibration results were not written |
End-to-End Verification
At this point, the hardware and calibration are ready. Proceed to the server side to run the full pipeline. For detailed commands, see the "Develop with the SDK" page (Windows / Linux).
Troubleshooting
Symptom | Possible Cause | Resolution |
|---|---|---|
Flowbit Capture does not discover cameras | Different subnets; mDNS service not running; firewall blocking UDP 5353; switch port isolation | Confirm same subnet, start Bonjour/avahi, allow the port, disable isolation |
Some cameras drop offline or reconnect repeatedly | Insufficient PoE power; poor quality or excessively long Ethernet cable; switch port fault | Verify PoE power budget, use Cat6 solid-copper cables, test with a different port |
Multi-camera point clouds are not aligned or are layered | Sensor-to-World extrinsic parameters are incorrect or have not been written back | Recalibrate and reconnect devices in Capture to write back extrinsics |
Streaming interruptions or incomplete groups after enabling sync | Device firmware and server version mismatch; camera clocks have not converged | Update all to version 1.5.0; check the sync/lag metrics in the Performance panel per Section 1.3 |
Flowbit Capture fails to launch or cannot decode | GStreamer is not in | Add GStreamer to |
On-Site Delivery Checklist
All cameras are powered on, connected to the network, and indicator LEDs are normal
Camera mounting positions are secured, angles are locked, detection range ≤ 5 m, and overlapping fields of view are established
Calibration is complete, extrinsic parameters have been written back to the cameras, and multi-camera point clouds are aligned
Performance panel shows per-camera sync close to 30 Hz and lag under 1000 ms, with no sustained degradation during extended operation
Flowbit Capture displays images correctly with real-time capture and rendering at 30 fps
On-site configuration backup: the
config/directory (including allconfig/<device-id>/subdirectories) has been archived